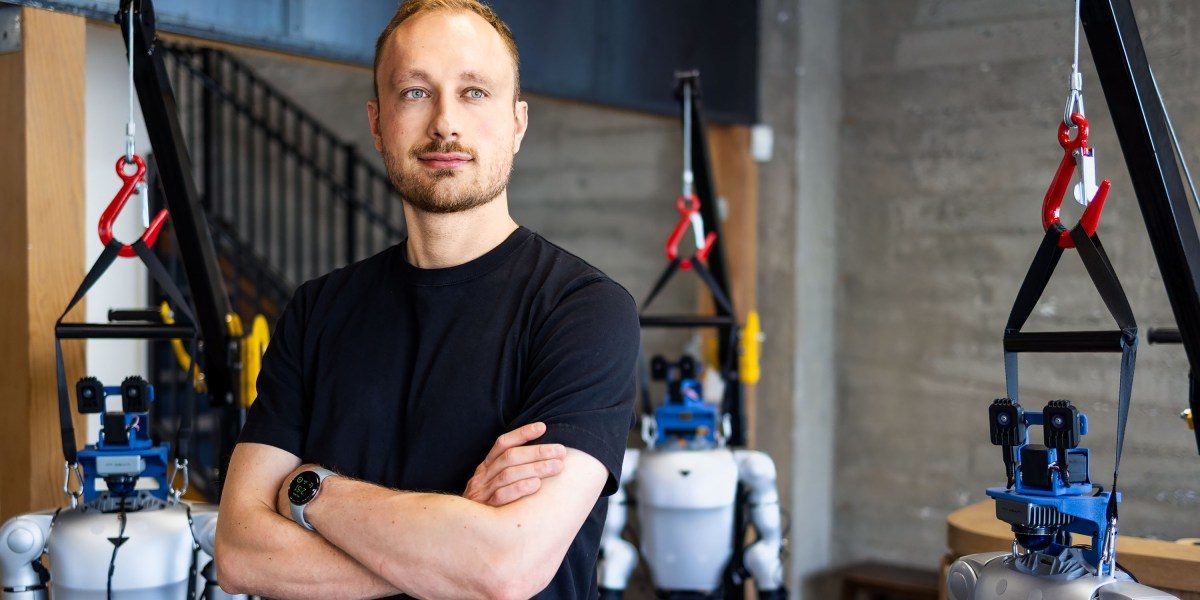
Danijar Hafner, a former Google DeepMind researcher who worked alongside AI pioneers like Geoffrey Hinton, has launched a stealth startup in San Francisco focused on advanced robotics. The venture aims to enable physical humanoid robots to react to novel, unseen physical environments using model-based reinforcement learning. Hafner has imported humanoid robots from China to test his techniques.
Hafner’s methodology centers on building world models—AI systems designed to emulate physical reality—and training autonomous agents within them. The agents treat these simulations as real-world environments to predict future outcomes and execute complex tasks without requiring extensive real-world trial-and-error training.
The venture represents an evolution of Hafner’s previous academic breakthroughs, such as the PlaNet planning model and Dreamer 2, which previously demonstrated human-level performance in complex virtual tasks.
Why it matters
World models are emerging as a core architecture to solve zero-shot real-world generalization in physical robotics.
Model-based reinforcement learning reduces the need for costly physical trial-and-error training in real environments.
Top-tier talent from frontier labs like DeepMind continues to spin out to build specialized physical AI startups.
Source: technologyreview.com