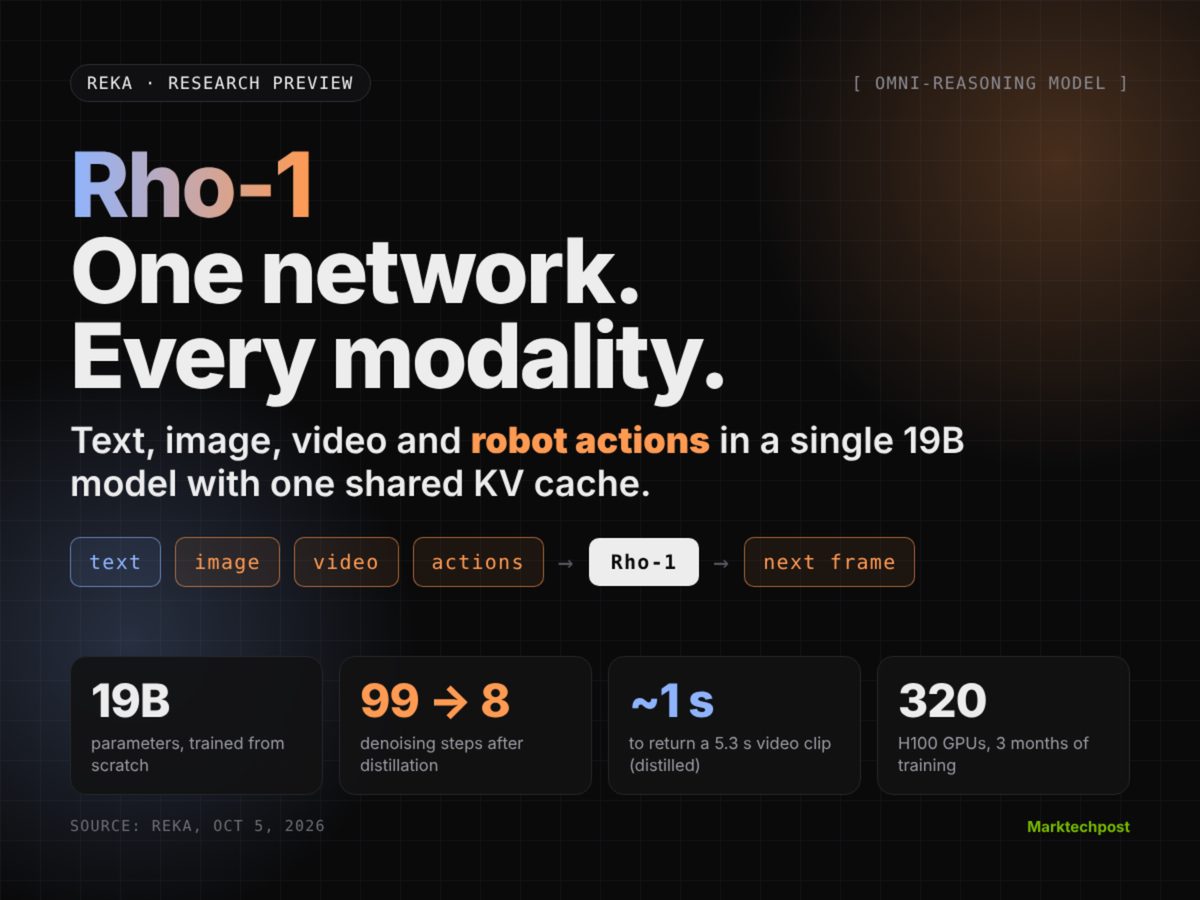
Reka has unveiled a research preview for Rho-1, a 19-billion parameter omni-reasoning model trained from scratch. The unified architecture handles text, images, video, and direct robotic control within a single neural network, bypassing traditional multi-agent pipelines. According to Reka, the model combines understanding and generation into a single context window using twin expert streams inside each transformer block.
In internal testing, the model successfully generated visual media, edited content, and outputted robotic movement instructions across 7 action channels without calling external tools or modular models. Reka implemented flow matching for continuous outputs alongside standard next-token prediction, allowing the model to produce video at 0.79x real-time speed. A distilled variant reduced denoising steps from 99 to 8, generating video clips in roughly one second.
To overcome limits in physical robotic training data, Reka paired Rho-1 with an Inverse Dynamics Model designed to extract control signals directly from video sources. Reka position the unified model as a faster alternative to multi-model agentic pipelines, citing reduced latency and shared key-value cache efficiency.
Why it matters
Developers can reduce latency by replacing complex multi-model pipelines with unified omni-reasoning networks.
Robotics teams can leverage raw video data using inverse dynamics models to overcome teleoperation data shortages.
AI architects gain efficiency by sharing context across generation and understanding streams inside single transformers.
Source: marktechpost.com