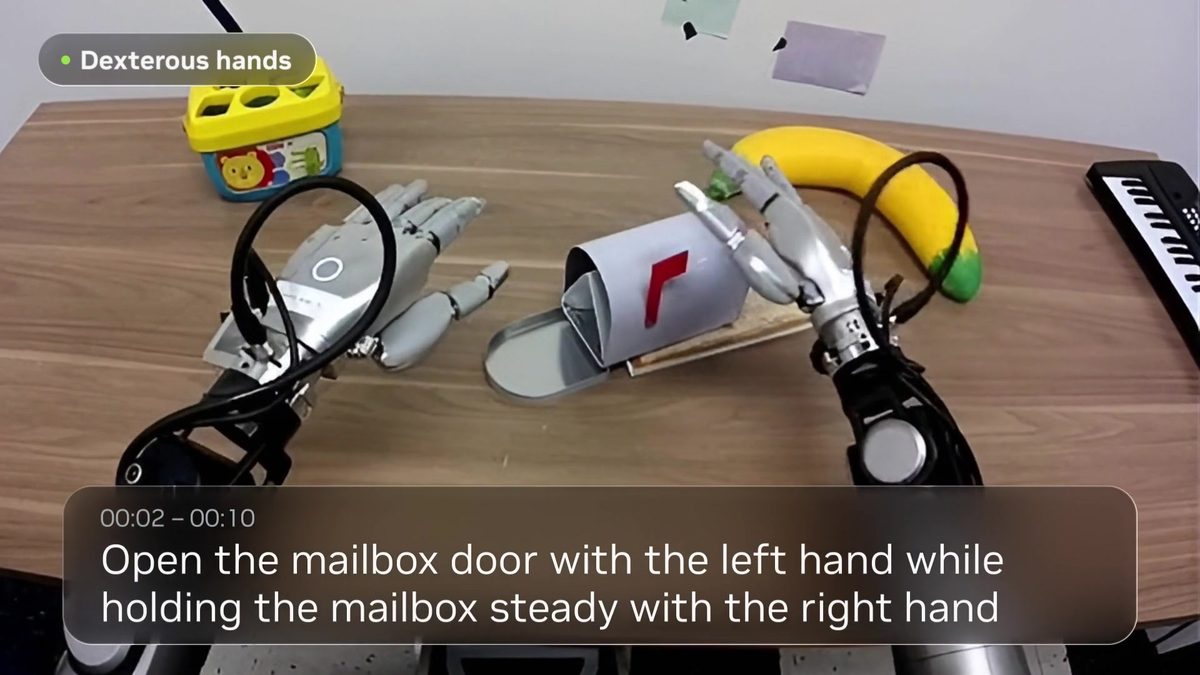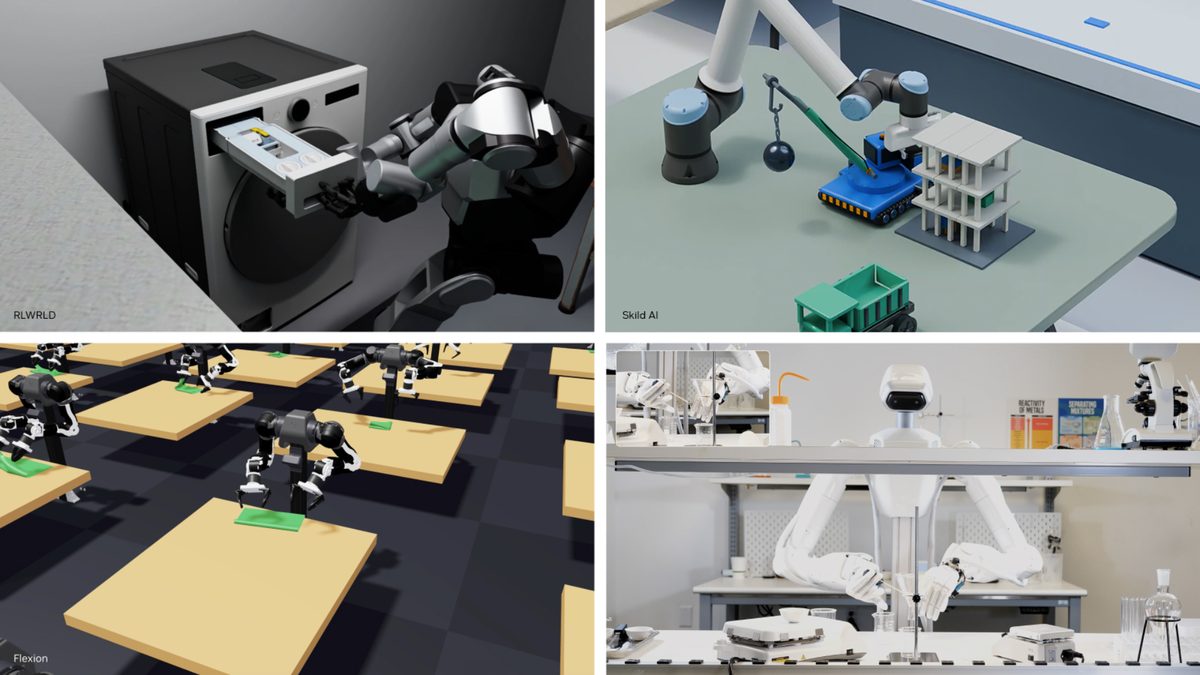
At the Conference on Robot Learning (CoRL) in Austin, Texas, NVIDIA introduced new open technologies designed to transition robotics from locomotion to fine-touch manipulation tasks, such as gear alignment and cable installation. The company unveiled GR00T 2, an open frontier world action model built on NVIDIA Cosmos and trained on 100,000 hours of egocentric human data to help robots execute complex, dexterous operations.
NVIDIA also released updates to its Isaac Lab 3.0 open-source framework, featuring tighter integration with the Newton physics solver and reinforcement post-training libraries. Partners including Foxconn, Siemens, Nexuni, and MicroAGI are currently testing these technologies to automate factory assembly lines, laundry handling, and server rack wiring.
Why it matters
Open world action models like GR00T 2 lower the barrier for robotics startups to deploy dexterous manipulation in industrial settings.
Enhanced physics simulation frameworks allow teams to post-train and evaluate complex physical policies before deploying to hardware.
Source: blogs.nvidia.com