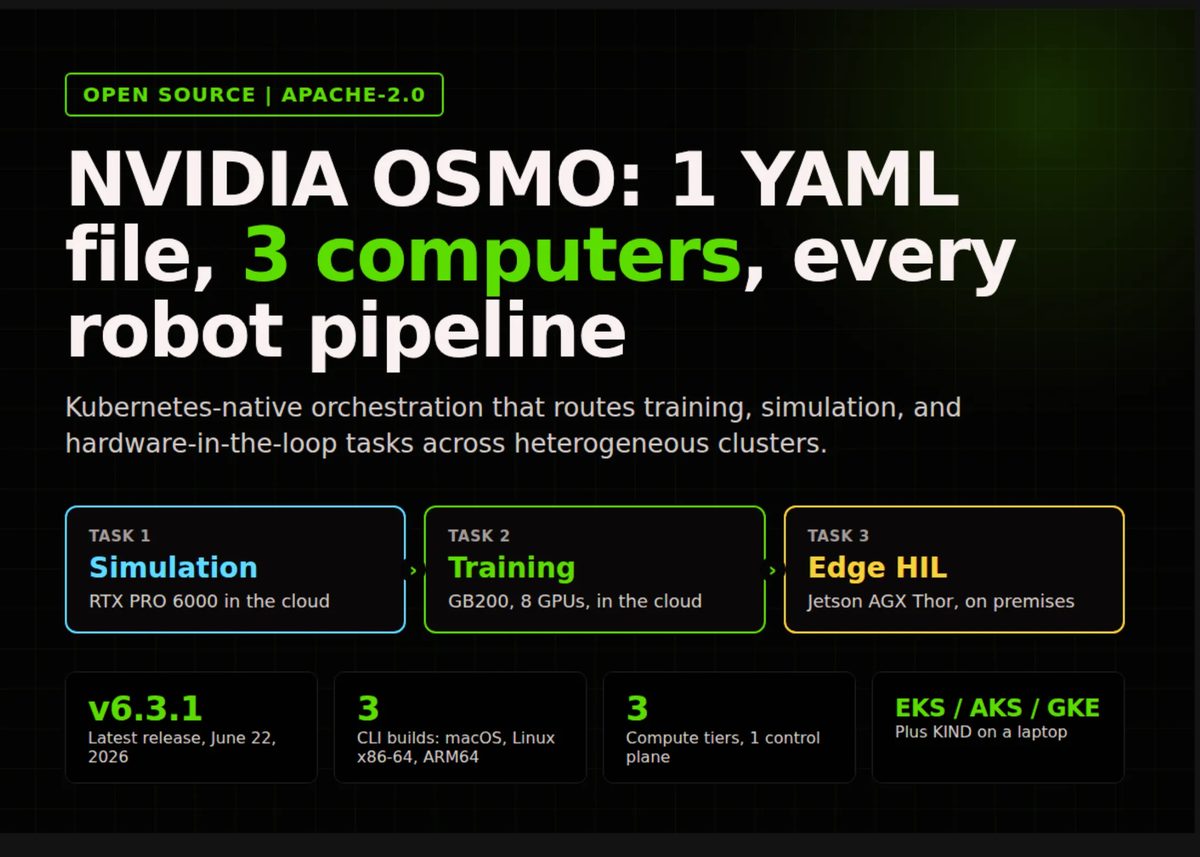
NVIDIA has released OSMO, an open-source, Kubernetes-native workflow orchestrator distributed under an Apache-2.0 license. The tool is designed to unify the three distinct compute tiers required for physical AI development: data-center GPU clusters for training, workstation RTX GPUs for simulation, and edge hardware such as the Jetson AGX Thor for real-world validation. OSMO allows engineering teams to define multi-tier compute workflows inside a single YAML file without writing custom infrastructure code.
The orchestrator functions as a single control plane across registered Kubernetes clusters. Workflows specify hardware platform targets—such as GB200, RTX, or Jetson pools—rather than explicit cluster names, allowing OSMO to handle task routing, Jinja-based templating, retry logic, and resource preemption automatically. Deployments include Helm charts, container images on NGC, and local quickstart configurations using KIND.
Why it matters
Robotics startups can eliminate custom infrastructure scripts linking training, simulation, and edge testing environments.
DevOps engineers gain a unified Kubernetes-native platform for dynamic resource borrowing across disparate GPU tiers.
Hardware teams can streamline hardware-in-the-loop validation directly within standard CI/CD deployment pipelines.
Source: marktechpost.com