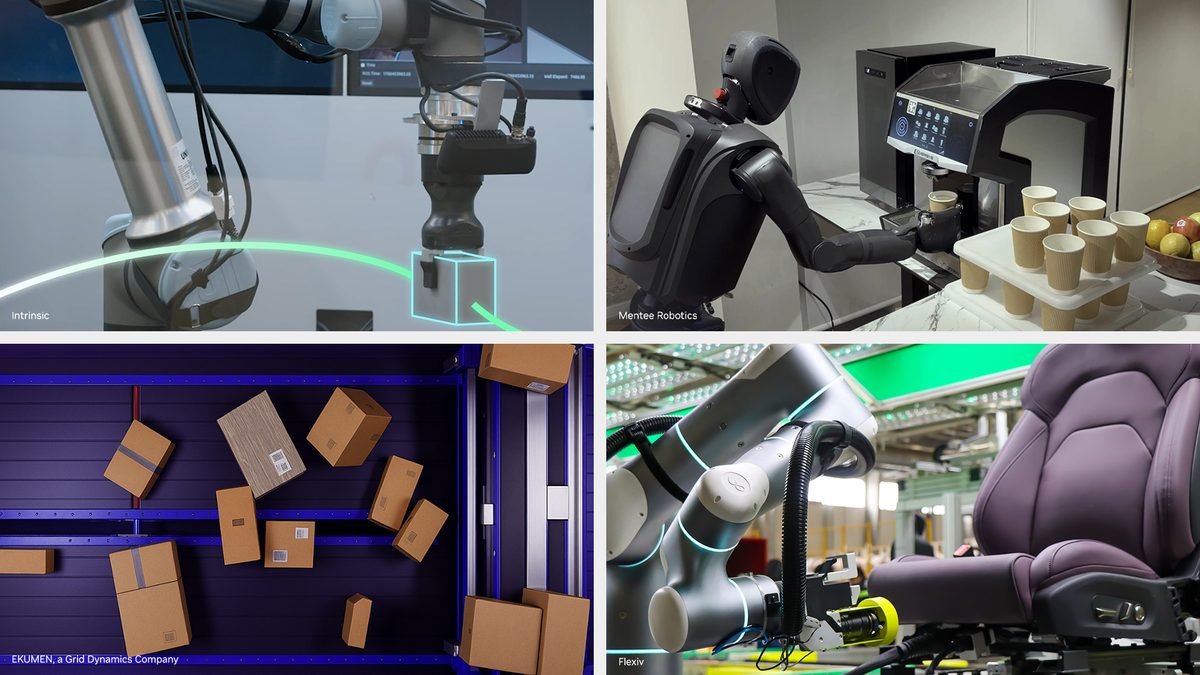
NVIDIA introduced Isaac ROS 5.0 today at the ROSCon conference in Toronto, launching a suite of GPU-accelerated packages designed for the open-source Robot Operating System. The release brings agentic development tools and physical AI models to the nearly 1.3 million developers within the ROS ecosystem.
Isaac ROS 5.0 adds platform support for ROS Lyrical and Ubuntu 24.04, alongside standardized data-handling interfaces developed with the Open Source Robotics Alliance. The software provides reusable agent-ready skills for system setup, pick-and-place manipulation, and stereo vision fine-tuning, allowing AI agents to automate software workflows and code adaptation for robotics engineers.
Additionally, NVIDIA updated its FoundationPose object pose estimation model to deliver up to 5.5x faster tracking performance. Ecosystem partners like RealSense are adopting the software alongside NVIDIA Nemotron open models to enable autonomous agents to control and interact directly with ROS-based hardware systems.
Why it matters
Agentic AI workflows are expanding into physical robotics, automating model fine-tuning and complex manipulation code.
GPU-accelerated open-source libraries significantly decrease tracking latency for physical AI and spatial computer vision applications.
Source: blogs.nvidia.com