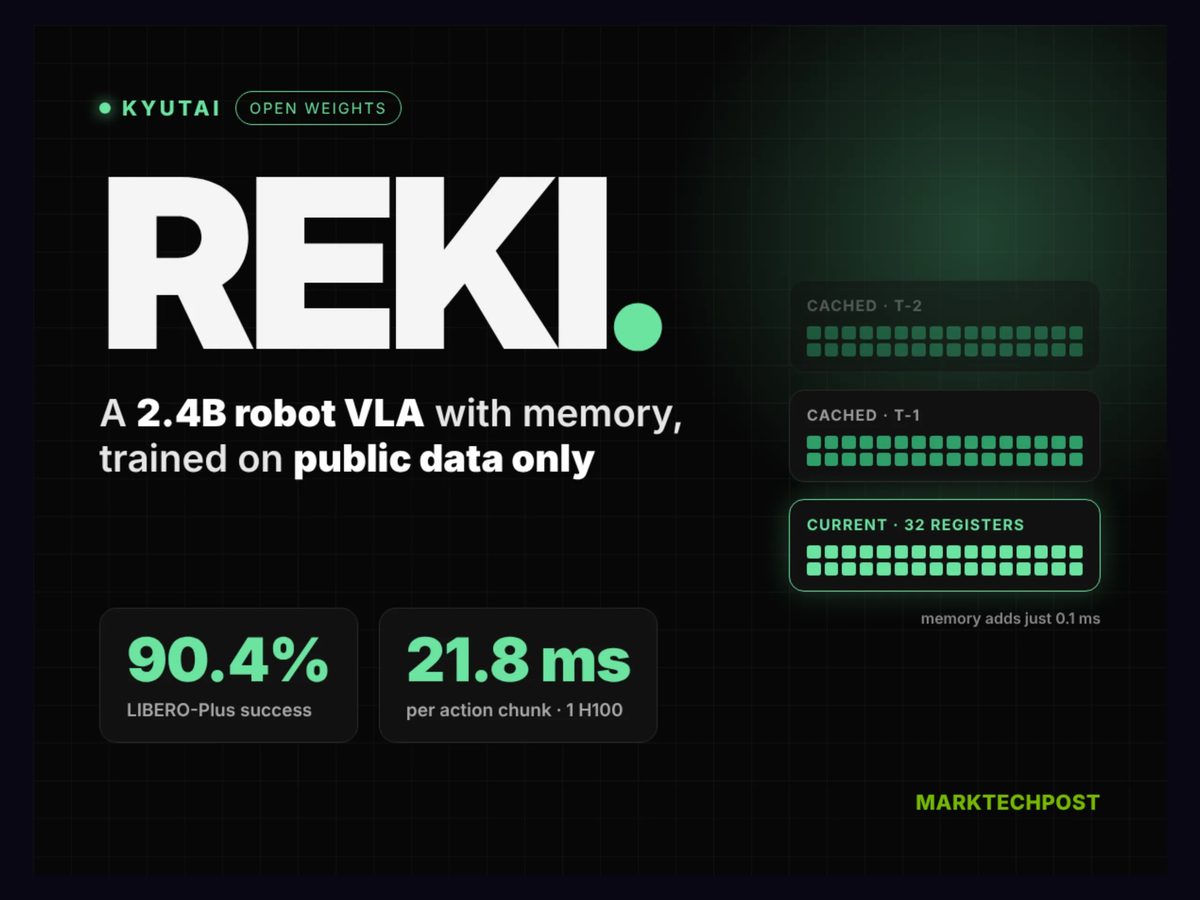
French AI research lab Kyutai, alongside Inria and École des Ponts, has released REKI, a 2.4-billion-parameter vision-language-action (VLA) model designed for robotic manipulation. Built on a Qwen3.5-2B backbone and a 200M-parameter action expert, the open-weights model rivals systems double its size across out-of-distribution benchmarks.
REKI incorporates a low-cost memory architecture directly into its action expert using 32 learned register tokens per frame. By caching observation history without reading action tokens, the model eliminates perceptual aliasing, reducing arm oscillation errors on the RoboTwin benchmark from 18.6 percent to 4.1 percent.
Pretrained on 1 billion frames of simulation, teleoperation, and human video datasets on 32 NVIDIA H100 GPUs, REKI supports real-robot deployment via the LeRobot async-inference protocol. All model weights and finetuned checkpoints have been published on Hugging Face for public research and engineering use.
Why it matters
Open-source, memory-efficient VLA models enable robotics startups to deploy robust manipulation control on lower-cost hardware.
Short-term memory caching solves common physical oscillation issues without incurring prohibitive computational overhead during inference.
Source: marktechpost.com