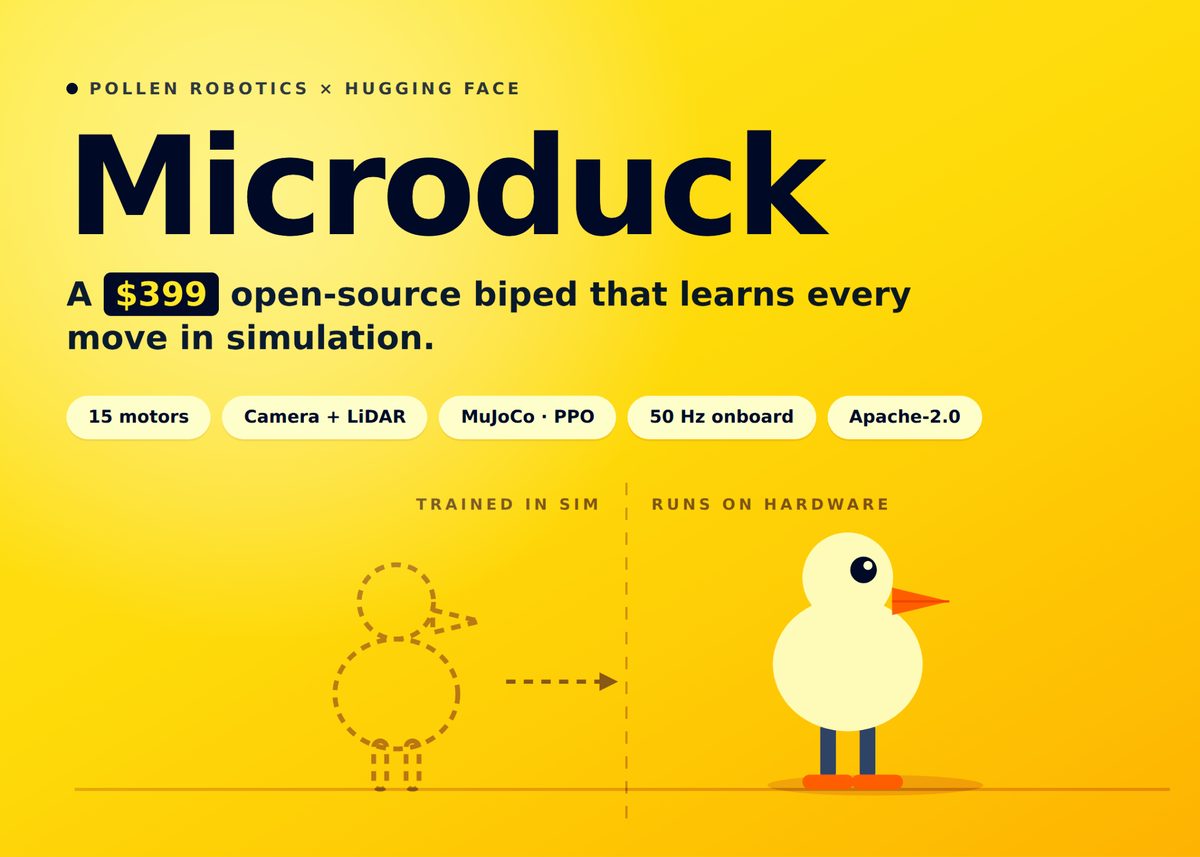
Pollen Robotics, the Bordeaux-based team at Hugging Face, has opened pre-orders for Microduck, a 25 cm bipedal robot priced at $399. Unlike standard hardware launches that rely on pre-recorded demonstrations, Microduck ships complete with its open-source training loop, physics simulator environments, and reward functions published publicly on GitHub. The unit features 15 joint motors, a complete sensor array including LiDAR, dual IMUs, and cameras, and runs on a Rockchip RK3566 processor with a dedicated AI accelerator.
Microduck’s locomotion and motion control are driven entirely by neural policies trained via reinforcement learning in MuJoCo Warp environments. To bridge the gap between simulation and real-world deployment, the team implemented detailed actuator models accounting for voltage sag, friction dynamics, and gear backlash. Checkpoints export directly to ONNX format and run locally via a Rust runtime, executing control loops at 50 Hz.
The launch highlights Hugging Face’s expanding footprint in open-source robotics and accessible hardware platforms. By distributing both the hardware and the complete sim-to-real training pipeline, the project provides developers and researchers with an end-to-end sandbox for developing and hot-swapping bipedal control policies.
Why it matters
Lowers the cost barrier for robotics developers by delivering an open-source, RL-trainable bipedal hardware platform for under $400.
Demonstrates a viable sim-to-real pipeline by publishing complete reward functions, environment randomizations, and ONNX runtime integration.
Expands Hugging Face’s footprint beyond software and cloud models into standardized open robotics hardware ecosystems.
Source: marktechpost.com